
4D imaging radar sensors
One software-defined radar platform, one integration you only learn once.
Products
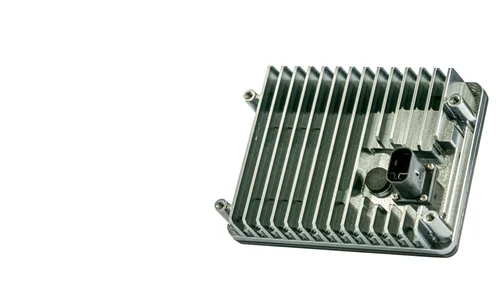
zPRIME 3.0
Ultra-performance 4D software-defined imaging radar for physical AI, robotics and intelligent infrastructure
- Field of view
- 120° × 24–90°
- Angular resolution
- 0.35°
- Truck detection
- >1,000 m (LR)
- Weight
- 520 g
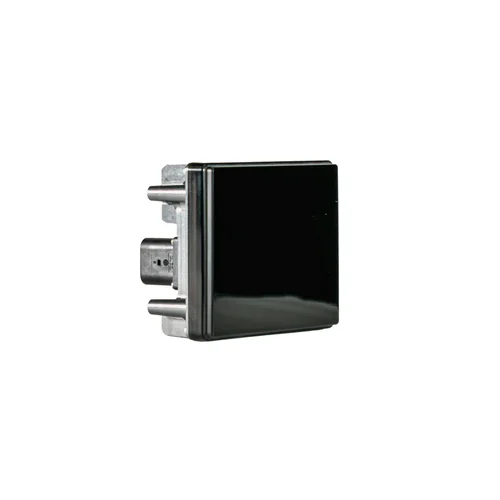
zPULSE 2.0
Compact, high-resolution 4D software-defined imaging radar with 120° × 90° field of view
- Field of view
- 120° × 90°
- Angular resolution
- 0.7° × 3.2°
- Truck detection
- >650 m
- Weight
- 250 g
zPULSE
Ultra-wide, compact 4D imaging radar for infrastructure and autonomous systems, in 60 GHz
- Field of view
- 120° × 90°
- Angular resolution
- 1.5°
- Truck detection
- >400 m
- Weight
- 250 g
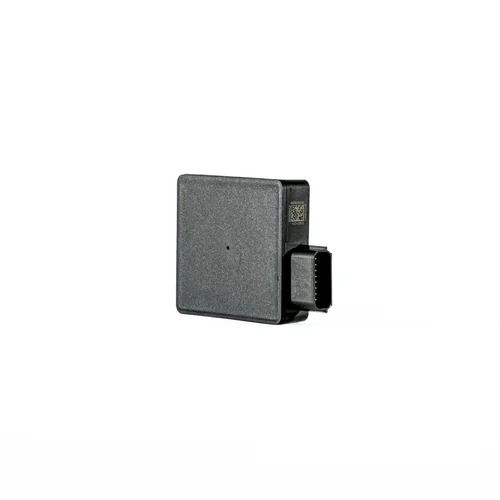
zSIGNAL
Compact 77 GHz 4D imaging radar for mass-market autonomous robotics
- Field of view
- Wide
- Angular resolution
- —
- Truck detection
- —
- Weight
- —
Overview
Every Zadar sensor is built on the same third-generation digital beamforming architecture and the SDIR (Software-Defined Imaging Radar) platform. Each one outputs a 4D point cloud of range, velocity, azimuth and elevation through the same interfaces, and every unit ships with Point Cloud Core. The sensors differ in reach, coverage and footprint, so you pick by the shape of the scene you need to see.
Comparison
| Part number | Frequency | FOV (H × V) | Static ang. resolution | Ang. accuracy | Truck detection | Human detection | Weight | Interface | Order |
|---|---|---|---|---|---|---|---|---|---|
| ZPRM3-77-T1-LRzPRIME 3.0 | 77 GHz | 120° × 24° | 0.35° × 0.4° | ±0.05° | >1,000 m | >180 m | 520 g | 1000BASE-T1 | Order now |
| ZPRM3-77-T1-WzPRIME 3.0 | 77 GHz | 120° × 50° | 0.35° × 0.9° | ±0.05° | >400 m | >120 m | 520 g | 1000BASE-T1 | Order now |
| ZPRM3-77-T1-UWzPRIME 3.0 | 77 GHz | 120° × 90° | 0.35° × 1.6° | ±0.05° | >250 m | >80 m | 520 g | 1000BASE-T1 | Order now |
| ZPULS2-77-T1UWzPULSE 2.0 | 77 GHz | 120° × 90° | 0.7° × 3.2° | ±0.05° | >650 m | >140 m | 250 g | 1000BASE-T1 | Order now |
| ZPULS-60-T1UWzPULSE | 60 GHz | 120° × 90° | 1.5° | ±0.25° | >400 m | >200 m | 250 g | — | Order now |
| ZSIG2-77-CAN-WzSIGNAL | 77 GHz | Wide FOV | — | — | — | — | — | — | Order now |
Software platform
Included with every sensor
Point Cloud Core
Flexible operating modes, 4D point cloud output, configuration and data APIs, PTP time sync, and SDKs for C++, Python, ROS 1 and ROS 2.
Build your own perception
RDP Developer
Data-processing toolboxes for building a custom radar perception stack on top of Zadar point clouds.
Advanced RF control
RSP Studio
Configure, visualize, analyze and optimize RF parameters and signal processing for advanced teams.
Tell us your application, we’ll suggest a sensor.
- 01Sensing application
- 02Coverage area
- 03Smallest object you must detect
- 04Weather and environment
Downloads
Data sheets, integration guides, software and SDK packages.
Frequently asked questions
Answers on SDIR, interfaces, synchronization, certification and deployment.